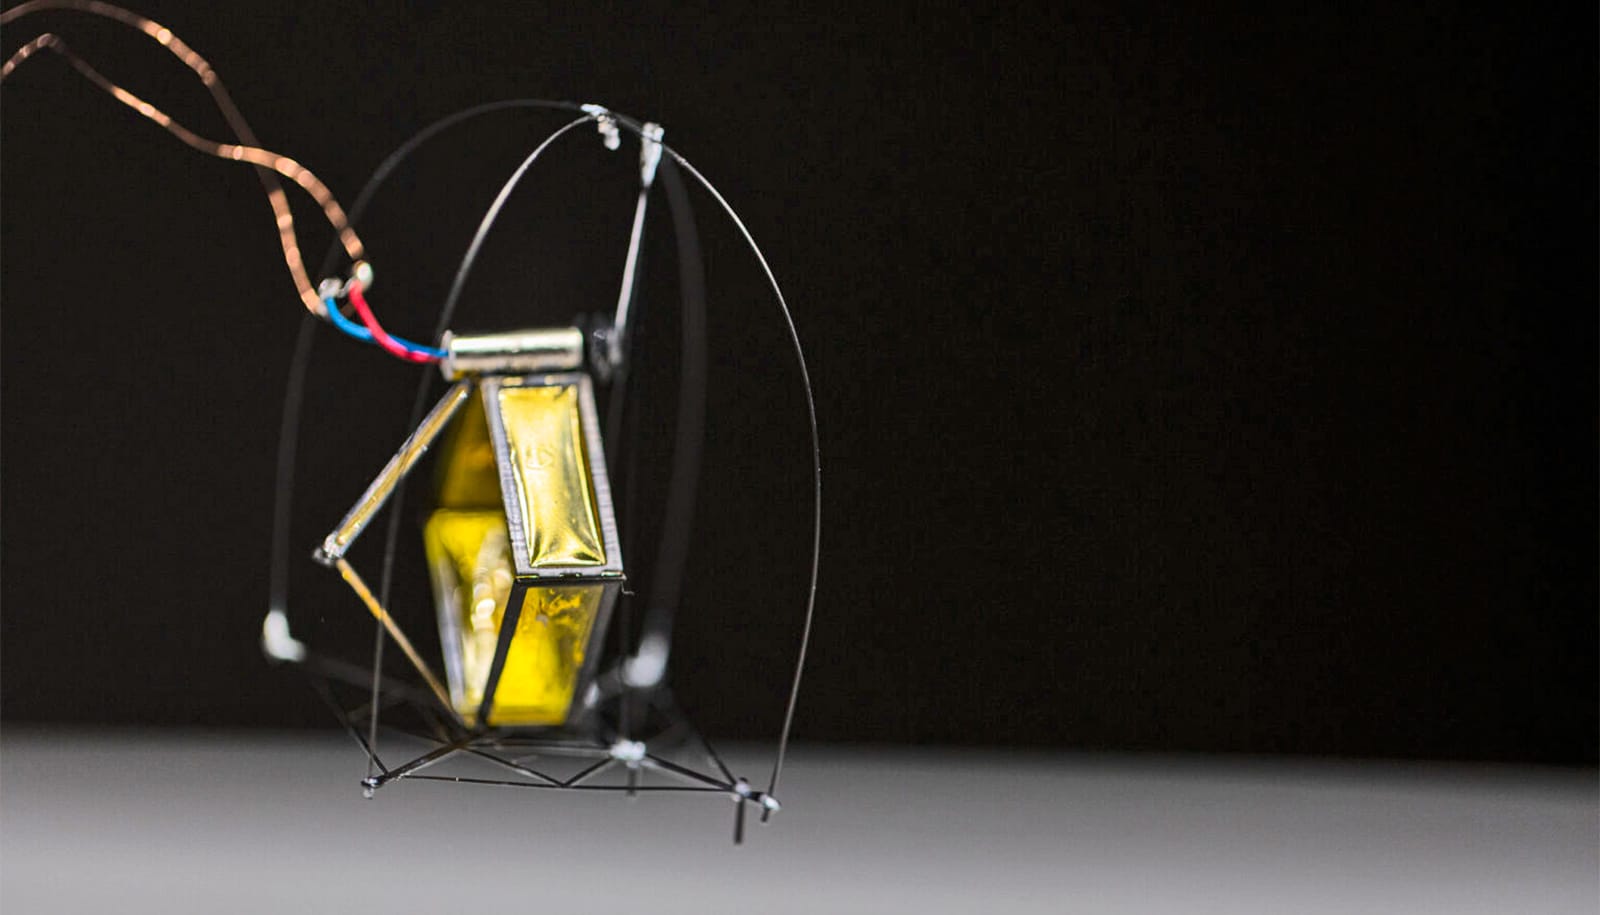
Engineers at the University of Washington built a one-gram robot called DirectHop that uses a direct-drive electric motor instead of traditional springs. By controlling the current to the motor, the robot can jump to a specified height with single-centimeter accuracy and clear a standard stair step. After landing inside a protective roll cage, it uses a mechanical shift in its center of gravity to right itself 90 percent of the time.
Spring-loaded mechanisms are notoriously difficult to calibrate at small scales, making this direct-drive approach a sensible workaround for precise locomotion. The prototype is still tethered to external power wires and lacks active steering, so autonomous navigation remains a distant goal. Even so, the prospect of manufacturing simple, semi-disposable hopping units for roughly ten dollars each makes the concept worth watching past the initial lab phase.


Leave a comment